问题描述:
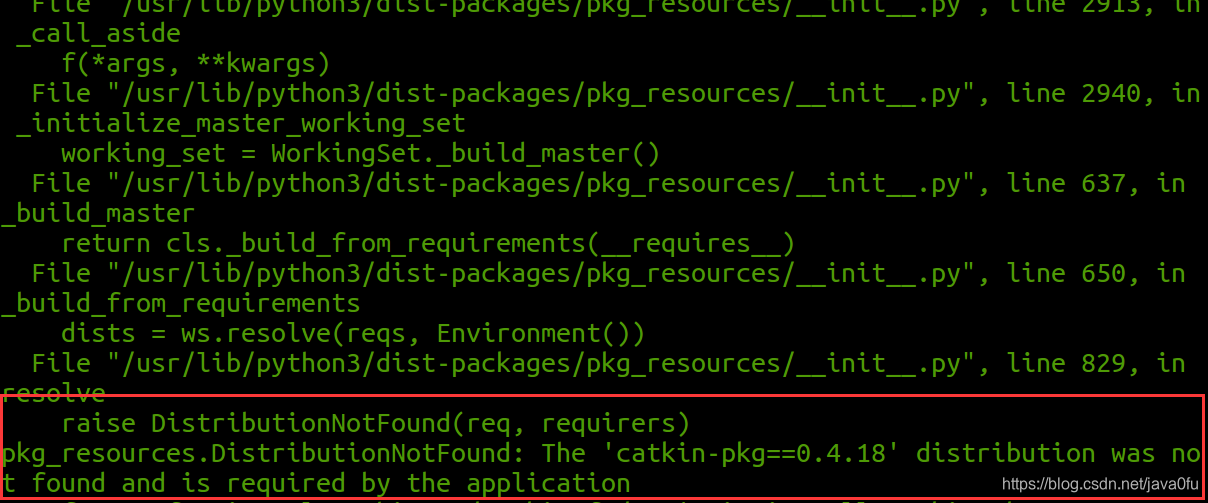
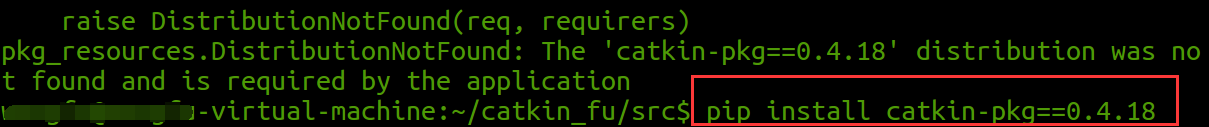
解决方案:
pip install catkin-pkg==0.4.18
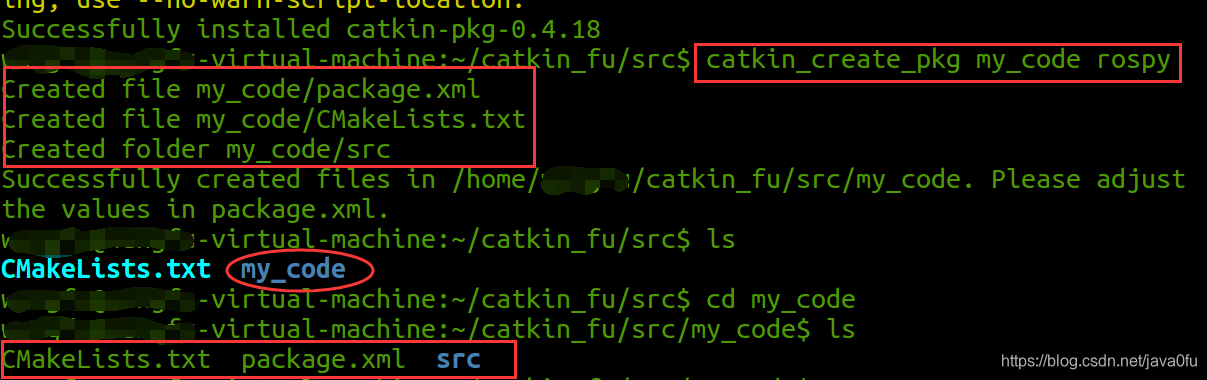
安装完成后便可创建ROS程序包。


 墨衍会员
·
AI 创作全网分发
墨衍智能分发
本文由作者通过墨衍一键同步至各平台
1分发平台
2k累计阅读
2.1k平均单平台
已同步平台
优快云
微信公众号
微博
知乎
掘金
百家号
博客园
抖音
小红书
你的文章也可以这样分发
墨衍会员 ¥399起/年,写一次发全网
我也要
问题描述:
解决方案:
pip install catkin-pkg==0.4.18
安装完成后便可创建ROS程序包。
【Pyinstaller】pyinstaller 打包出现几类错误的一般解决方法(不定时更新)
笔者的错误如下: 在用pyinstaller打包(-D 选项),如果用到的第三方库含有data文件,而pyinstaller又没有自带该第三方库文件的hook的时候,执行打包后的exe一般会报以下错误 FileNotFoundError: [Errno 2] No such file or directory: 'd:\\anaconda3\\envs\\tensorflow2\\lib\\site-packages\\pyyaml-5.3.1-py3.6-win-amd64.egg\\EGG-INFO\\
pip3 报错 distribution was not found and is required by the application
显示: pip 21.2.4 from /usr/local/python3/lib/python3.10/site-packages/pip (python 3.10)因此将【pip3文件中的版本号】修改成【python3的pip3的版本】,然后保存即可。如果存在旧版本的python3软连接,就修改软连接, 在ln命令后面加上 nf参数。原因: python3的pip3的版本与 pip3文件中的版本号不一致。创建目录: /usr/local/python3。python3的pip3的版本。
LVDS系列11:Xilinx Ultrascale系可编程输入延迟(一)
按照IDELAYCTRL的参考时钟频率可以准确计算获取到,如200M参考时钟抽头分辨率为78ps,Ultrascale系列相对于7系列架构大改,体现便是U/U+系列的抽头增加到512个,同时每个抽头的分辨率就无法像7系列那样能得到一个准确的值,是一个波动的范围值,抽头分辨率随着工艺温度电压的变化而变化。EN_VTC:电压温度补偿开启的使用信号,COUNT模式下不能使用,必须保持为0,TIME模式下需要使用,在延迟工作时要启用温度电压补偿,在修改抽头值时需要关闭温度电压补偿,修改完后启用;
解决 The 'supervisor==3.2.0' distribution was not found and is required by the application错误
ubuntu16.04 修改默认 python 为 anaconda3 后 supervisor.service 报如下错误 Oct 11 09:06:37 zhangyinglong-PC systemd[1]: supervisor.service: Service hold-off time over, scheduling restart. Oct 11 09:06:37 zhangyin...
ROS2机械臂MPC轨迹规划实战:从MoveIt 2插件配置到参数调优全流程
本文详细介绍了ROS2机械臂MPC轨迹规划的全流程,从MoveIt 2插件配置到参数调优。通过模型预测控制(MPC)技术,实现高精度运动控制,特别适合复杂装配任务。文章包含环境搭建、插件部署、参数设计及实战调优方法,帮助开发者快速掌握ROS2机械臂的MPC轨迹规划技术。
GD32F450以太网(1):ETH 外设接口简介
GD32F450以太网ETH MAC外设接口简介
catkin-build时:pkg_resources.DistributionNotFound: The ‘X’ distribution was not found and is required
ubuntu20.04,运行命令 sudo apt-get install python-catkin-tools 20.04运行:sudo apt-get install python3-catkin-tools 具体自己操作系统用python还是python3可以百度一下,很简单找到答案 正确安装之后,用catkin build编译包时,即运行命令 catkin build 包名 出现以下错误:: pkg_resources.DistributionNotFound: The 'os...
使用逻辑分析仪处理IIC信号
逻辑分析仪
Centos7在启动supervisor的过程中遇到pkg_resources.DistributionNotFound: The ‘supervisor==3.4.0‘的解决方法
需要修改这两个文件/usr/bin/supervisorctl 和 /usr/bin/supervisord 的开始行python调用路径,均改为 #!/usr/bin/python2
基于python的排课表系统,用python编写排课系统
实现一个具体的课程管理系统。(5) 学生可以查看自己选上的课的成绩,以及各个课程的得分、绩点,并给出其平均绩点,但不允许查看年级其他人的成绩。(2) 学生定制专属课表,可以查看整个学期本人的课程安排,包括课程名称、上课时间、上课地点、任课老师、学分等等。(13) 系主任可以查看整个系的全部学生以及他们的平均绩点,可以对每个班进行排名,或者也可以对整个系进行排名。(15) 系主任可以查看整个学期所开设的所有课程,包括这些课程的全部详细信息。(1) 学生基本信息的查询,学生可以对本人的系统登陆密码进行修改。
【温室气体数据集】CAMS 发布的温室气体(GHG)数据集总结
【温室气体数据集】CAMS 发布的温室气体(GHG)数据集总结
The 'docker-compose==1.8.0' distribution was not found and is required by the application
使用docker-compose时出现错误:The 'docker-compose==1.8.0' distribution was not found and is required by the application。 解决方法: 重新手动安装docker-compose sudo curl -L https://github.com/docker/compose/releases/down...
CDD数据库文件制作(十一)——服务配置(0x19_DTC Code)
虽然选择Copy和Reference都可以加载DTC,但是如果我们在DTC库中有修改DTC,通过Copy的方式加载的DTC在DTC Table中不会跟着DTC库的修改而自动更新。通过Reference的方式加载的DTC可以自动更新。找到Fault Memory的DTC Table,鼠标放在DTC Table区域,右键点击选择Copy …根据需要(客户协议)勾选响应的19服务子功能。如何创建一个新的DTC code?按照字母与下方要素可做一一对应。首先在DTC库中新建DTC。支持10 01/10 03。
【python】升级pip后报错解决pkg_resources.DistributionNotFound: The 'pip==7.1.0' distribution was not found an...
原本使用pip版本为7.1.0,后升级至9.0.1 之后使用pip list提示pkg_resources.DistributionNotFound: The 'pip==7.1.0' distribution was not found and is required by the application 解决方法: vim /usr/bin/pip ------------------- ...
linux平台Modbus TCP测试
【代码】linux平台Modbus TCP测试。
锂电池充电器电路设计 里面有电路
锂电池充电器电路设计 里面有电路 3.7V升压到5V电路设计。
pkg_resources.DistributionNotFound xxx was not found and is required by yarl
pkg_resources.DistributionNotFound ‘xxx>=3.7.4’ was not found and is required by yarl 既然说找不到xxx库,用pip list或者conda list查看,如果真的没有装,那么就安装它。
WINCC7.3破解文件
WINCC7.3硬件够破解文件,有需要的下载!WINCC7.3硬件够破解文件,有需要的下载!
错误:The ‘pycocotools>=2.0‘ distribution was not found and is required by the application
问题1: The ‘pycocotools>=2.0’ distribution was not found and is required by the application Windows10安装pycocotools方法,亲测可用! 如果遇到:No module named ‘pycocotools’ 错误,说明你的环境需要安装pycocotools,以下介绍在Windows10下安装pycocotools的方法,亲测可用 ,转载大佬的方法很有用。 从 https://github.com/p
Probability and Statistics - 4th edition
Probability and Statistics - 4th edition
Camera2Demo
在Camera2 的基础上进行封装,使得Camera2一堆初始化逻辑与Activity分离,降低耦合度,完成预览拍照并保存的操作
安装ROS后初始化时出现The ‘rosdep==0.19.0‘ distribution was not found and is required by the application错误
安装好ROS后,当初始化时,出现错误: @Inspiron-7447:~$ sudo rosdep init Traceback (most recent call last): File "/usr/bin/rosdep", line 6, in <module> from pkg_resources import load_entry_point File "/usr/local/lib/python3.5/dist-packages/pkg_resources/__init
yolov5环境搭建解决Microsoft Visual C++ 14.0 is required、DistributionNotFound:The ‘pycocotools>=2.0‘ dist问题
文章目录前言解决办法一 下载cocoapi二 安装环境三、最后重新回到安装环境 前言 在搭建yolov5的过程中,遇到的问题。 pkg_resources.DistributionNotFound: The ‘pycocotools>=2.0’ distribution was not found and is required by the application Microsoft Visual C++ 14.0 is required 错误提示直接下载:https://visualst
【debug】pkg_resources.DistributionNotFound:The ‘catkin-pkg==0.4.24‘ distribution was not found and...
2023/09/23 src中创建功能包时报错,记录报错内容和解决过程。
pkg_resources.DistributionNotFound: The 'catkin-pkg==0.4.9' distribution was not found
个人感觉是python2与python3在ros中的差异导致的, 问题一:Traceback (most recent call last): File "/usr/bin/rosdep", line 3, in <module> from rosdep2.main import rosdep_mainImportError: No module named 'rosd...
python打包exe报错 The ‘cryptography‘ distribution was not found and is required by the application
原因:依赖包cryptography丢失了。 解决办法: pip install cryptography
pyinstaller 打包程序 出现错误的解决方法
打开命令窗口进入到程序所在目录下 1.使用命令pyinstaller -p C:\Python27\Lib\site-packages\zmq SpiderTaskDistributor.py 打包程序 -p参数是添加的pyinstaller打包程序时的扫描路径,pyinstaller的扫描路径有可能不完整,造成打包后的可执行文件运行时出现“找不到指定的模块”的错误。 2.在当前目录下生成两
The 'pytz' distribution was not found and is required by Django解决办法
在创建第一个django项目时输入: django-admin startproject HelloWorld 报错: pkg_resources.DistributionNotFound: The ‘pytz’ distribution was not found and is required by Django 参考了网上很多方法都没有解决,最后解决办法是: 安装pytz模块(时区模块) p...
bug宝典Python篇 pkg_resources.DistributionNotFound: The ‘pip==7.1.0‘ distribution was not found and is
#安装pip tar -zxvf pip-9.0.1.tar.gz cd pip-9.0.1 python setup.py install 再执行pip --version,提示下面的异常[root@ceshi187 pip-9.0.1]# pip --version Traceback (most recent call last): File "/usr/bin/pip", line 5
python:pkg_resources.DistributionNotFound: The 'pip==1.5.4' distribution was not found ...
问题: unbuntu pkg_resources.DistributionNotFound: The 'pip==1.5.4' distribution was not found and is required by the application 解决: wget https://bootstrap.pypa.io/ez_setup.py -O - | sudo Pytho

 被折叠的 条评论
为什么被折叠?
 到【灌水乐园】发言



 2万+


 扫一扫


